Robotics & Automation
· May 27, 2026 6:01 AM EDT
Not market news
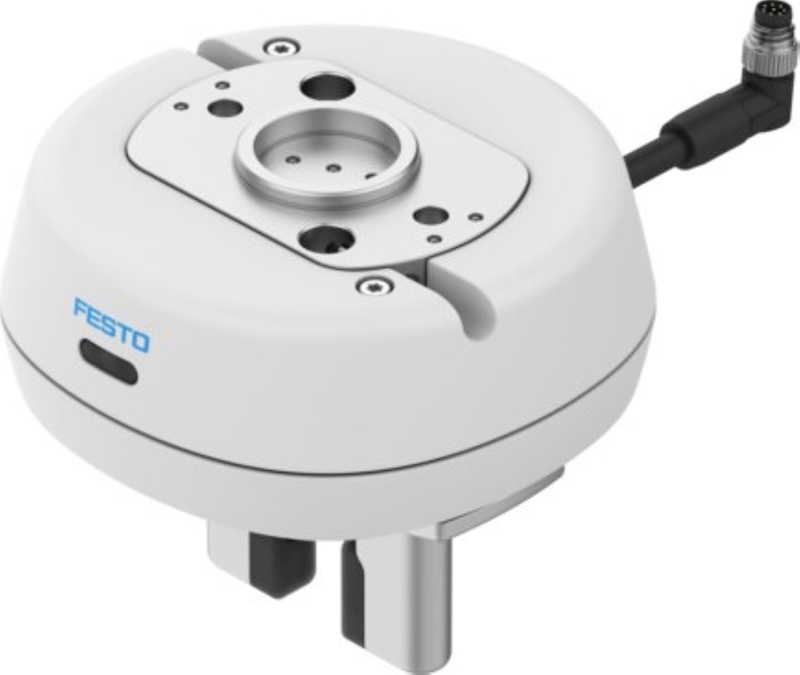
Festo introduces two-finger pneumatic gripper for cobot applications
Collaborative robots operate within strict payload and mounting constraints. Pneumatic gripper installations that rely on external valves, sensors, and wiring add weight, increase footprint, and complicate routing along compact cobot arms. To address these constraints, Festo has introduced the HPPH two-finger pneumatic parallel gripper, a compact, lightweight design that integrates control, sensing, and collaborativ…
AI brief
Pulse reads the full article- What happened
- Why it matters
- What to watch
Sign in to get the AI brief. Pulse explains what happened, why it matters, what to watch and who's exposed. Free for members.
Sign in to read the brief